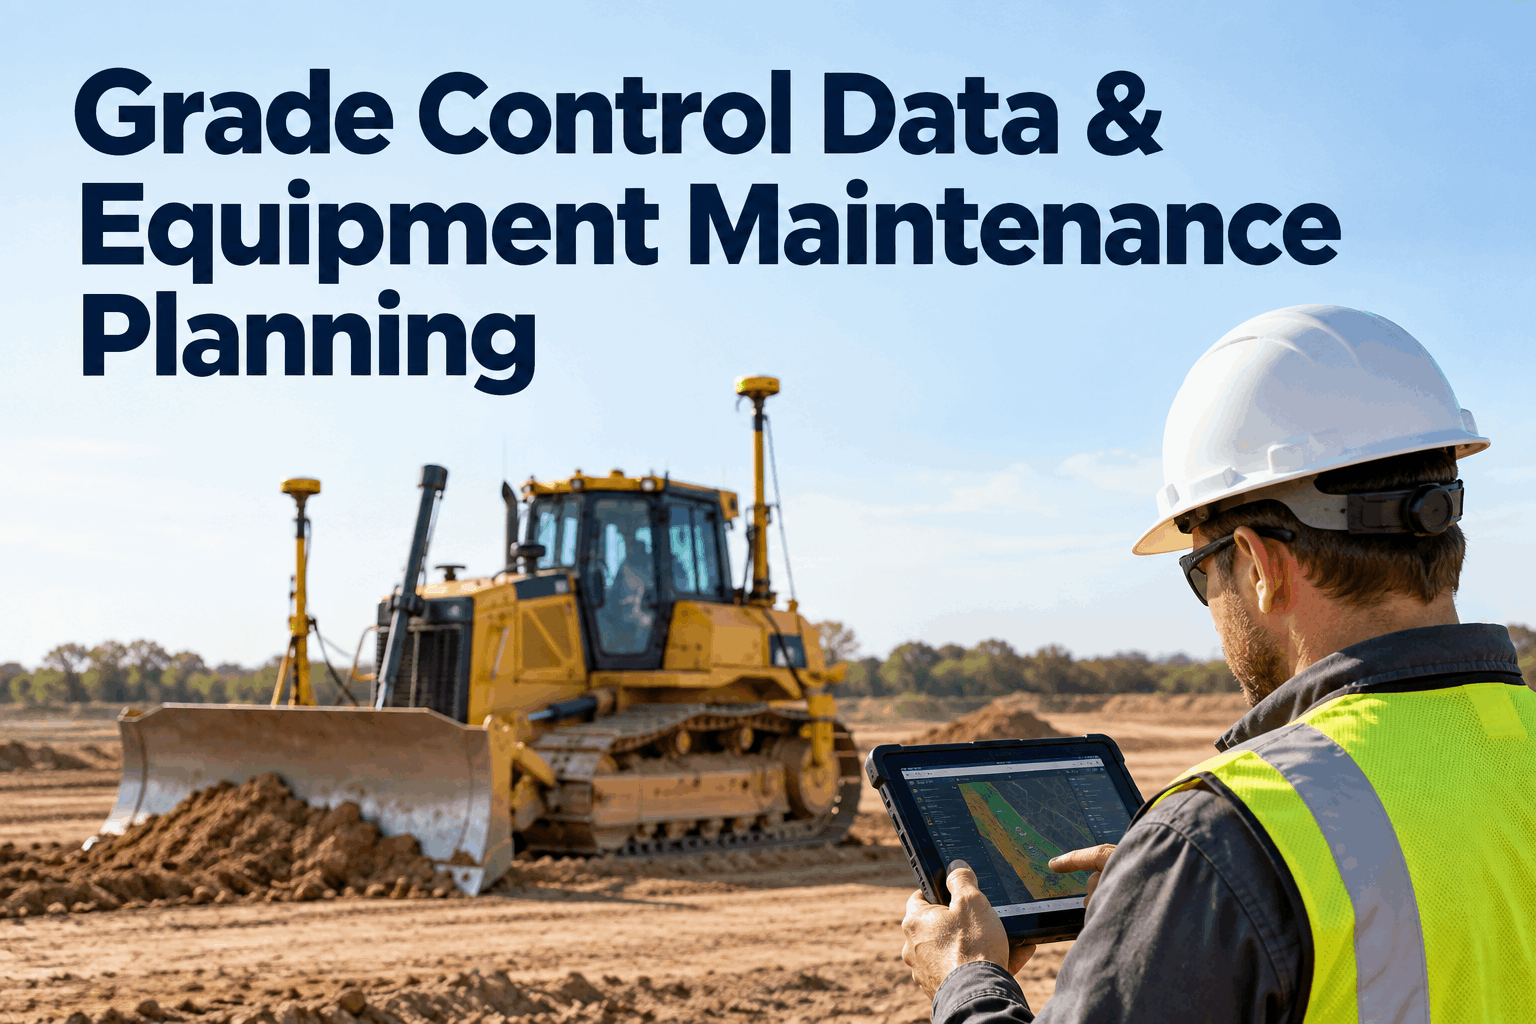
Two machines can run the exact same grade control software and still produce grading that's inches apart — not because one system is better, but because one was calibrated correctly and the other wasn't. Grade control calibration is a sequence, not a single setting, and skipping or rushing one step in that sequence is enough to undermine everything downstream of it. Here's how the sequence actually works, how to verify it held, and when it has to be redone.
Which Calibration Step Covers This?
Pick a calibration step. See what it configures and why skipping it undermines everything that comes after.
Configures: the physical dimensions of the blade, bucket or attachment and its exact mounting position on the machine.
Done first, because: every other calibration step calculates its values relative to this geometry — get it wrong and every downstream number inherits the error.
Configures: the precise distance and angle from the GNSS antenna's physical position to the cutting edge the system is actually trying to control.
Done after geometry, because: the offset calculation depends on the attachment dimensions already being correct in the system.
Configures: the inertial measurement unit's reference for "level" and its alignment to the machine's true orientation, not just its mounting bracket's orientation.
Done on stable, known-flat ground — calibrating an IMU on an uneven surface bakes that unevenness into every future reading.
Configures: how the hydraulic valves respond to the system's correction commands — how aggressively or gently the blade moves to close a grade error.
Done last, since it tunes the machine's physical response to a system that's already measuring correctly.
The Grade Control Calibration Sequence: Four Steps in Order
Grade control calibration isn't one procedure — it's four dependent steps, and the order matters because each one builds on the step before it. Run them out of sequence, or skip one because "it was fine last time," and the error doesn't announce itself. It just shows up later as a grading problem nobody can immediately explain.
Machine Geometry: Where Every Grade Control Calibration Starts
Before any sensor reading means anything, the system needs to know exactly what it's controlling — blade width and cutting-edge position on a dozer, bucket dimensions and pin geometry on an excavator, moldboard length and mounting points on a grader. These measurements get entered directly into the system during initial setup, and they're the foundation every other calibration step calculates against. A measurement error here doesn't cause an obvious failure; it causes a small, consistent offset that looks exactly like a sensor problem once the machine is back out grading, which is why geometry gets verified first whenever a calibration is questioned, not assumed correct.
IMU Zero and Alignment: Teaching the System "Level"
The inertial measurement unit is what tells the system the blade or bucket's real-time orientation between GNSS position updates, and its entire output depends on a correct starting reference for level. Zeroing an IMU on ground that isn't actually flat bakes that slope into every reading the sensor produces afterward — the system isn't wrong about what the IMU is telling it, the IMU itself was given bad information to start from. This is also where cross-slope and main-slope values get set on grader and dozer systems with dual-sensor configurations, since the system needs to know how the blade-mounted sensor relates to the body-mounted one before it can reconcile the two in real time.
Verifying a Calibration: The Pass-and-Reverse Method
A calibration that looks correct sitting still can still be wrong once the machine is actually grading, which is why the standard verification isn't a static check — it's a working test. Grade a finish pass in one direction, then turn the machine around and grade the same area from the opposite direction. If the two passes don't match, the calibration has a directional error that a stationary check would never have revealed, most commonly in the slope or cross-slope values rather than the GNSS positioning itself. Book a demo to see pass-and-reverse verification results logged against the calibration record, so a mismatch gets traced to a specific sensor instead of triggering a full system re-check from scratch.
When Recalibration Becomes Mandatory
| Event | Why it invalidates the calibration |
|---|---|
| Sensor replacement | A new IMU or GNSS unit has no stored reference — it starts from zero regardless of what the old one was calibrated to. |
| Attachment or bucket change | Machine geometry — step one in the sequence — has physically changed, invalidating every step calculated after it. |
| Component adjustment or repair | Hydraulic or linkage work can shift response characteristics even when no sensor was touched directly. |
| Impact or collision | Sensor mounts can shift internally without visible external damage to the housing. |
None of these require guessing whether a recalibration is needed — each one is a defined trigger, which is exactly why they're worth tracking as events rather than relying on someone remembering to flag it weeks later.
Documenting Calibration: Why the Record Matters More Than the Number
A calibration value by itself tells you almost nothing without history behind it. The question that actually matters when grading goes wrong isn't "what's the current calibration" — it's whether this specific machine has a pattern: the same sensor recalibrated repeatedly, the same attachment change triggering the same error every time, a verification pass that's failed on this unit before under similar conditions. That pattern is invisible without a record tying calibration and verification events to the individual machine over its working life, which is also what separates a one-off sensor fault from a systemic problem worth escalating past routine recalibration.
What an Equipment Technician Actually Watches For
Our old process was recalibrate, grade a few passes, call it good if it looked right. We stopped catching directional errors that way more often than I'd like to admit. Running the pass-and-reverse check every time, and actually writing down which step we recalibrated and why, changed that completely. Now when a machine comes back with a grading complaint, I can check its calibration history before I even walk out to look at it.
The Takeaway
Grade control calibration holds up when it's treated as an ordered sequence — geometry, GNSS offset, IMU alignment, hydraulic response — verified with a working pass-and-reverse test rather than a static check, and documented well enough to trace a recurring problem back to a specific machine and step. Skipping the order or the verification doesn't usually cause an obvious failure; it causes a quiet, consistent error that costs rework before anyone traces it back to where it actually started. Sign up free and start tying every calibration event to the machine it belongs to.
Frequently Asked Questions
What are the main steps in grade control system calibration?
Grade control calibration typically follows four dependent steps in order: machine geometry (entering blade, bucket or attachment dimensions and mounting position), GNSS antenna offset (the distance and angle from the antenna to the actual cutting edge), IMU zero and alignment (establishing the inertial sensor's reference for level), and hydraulic response tuning (how the valves respond to correction commands). Each step calculates its values relative to the one before it, so performing them out of order or skipping one undermines everything calculated afterward.
How is a grade control calibration actually verified?
The standard verification method is a working test rather than a static check: grade a finish pass in one direction, turn the machine around, and grade the same area from the opposite direction. If the two passes don't match, there's typically a directional error in the slope or cross-slope calibration that a stationary check wouldn't reveal, since the error only becomes apparent once the machine is actually grading under real conditions.
Why does IMU zeroing need to happen on flat, stable ground?
The inertial measurement unit establishes its reference for "level" during the zeroing process, and whatever surface it's zeroed on becomes its baseline. If that surface isn't actually flat, the resulting slope is baked into every subsequent reading the sensor produces — the IMU will report accurately relative to a false baseline, which looks identical to a sensor malfunction once the machine is grading.
What events require a grade control system to be recalibrated?
Recalibration is typically required after sensor replacement (a new unit has no stored reference), an attachment or bucket change (machine geometry has physically changed), hydraulic or linkage component adjustment or repair (which can shift response characteristics), and any impact or collision, since sensor mounts can shift internally without visible external damage.
Why is documenting calibration history important, not just the calibration itself?
A single calibration value provides little insight without context. Documented history reveals patterns — the same sensor needing repeated recalibration, a specific attachment change consistently triggering the same error, or a verification pass failing on the same machine under similar conditions before. That pattern is what distinguishes a one-off sensor issue from a systemic problem worth escalating, and it's invisible without records tying calibration and verification events to the individual machine over time.
Give Every Calibration Event a Record Worth Trusting
HVI logs machine geometry, calibration steps and pass-and-reverse verification results against each machine's service history, so a grading problem gets traced to a specific step and asset instead of a full system guess.
No credit card · No hardware required · Live before your next grading job